03 · Position, orientation & time
Navigation & Sensor Fusion
Integrated GNSS/INS, trajectory, timing, and sensor workflows that position dynamic observations precisely.
What we solve
From a client problem to a clear spatial framework.
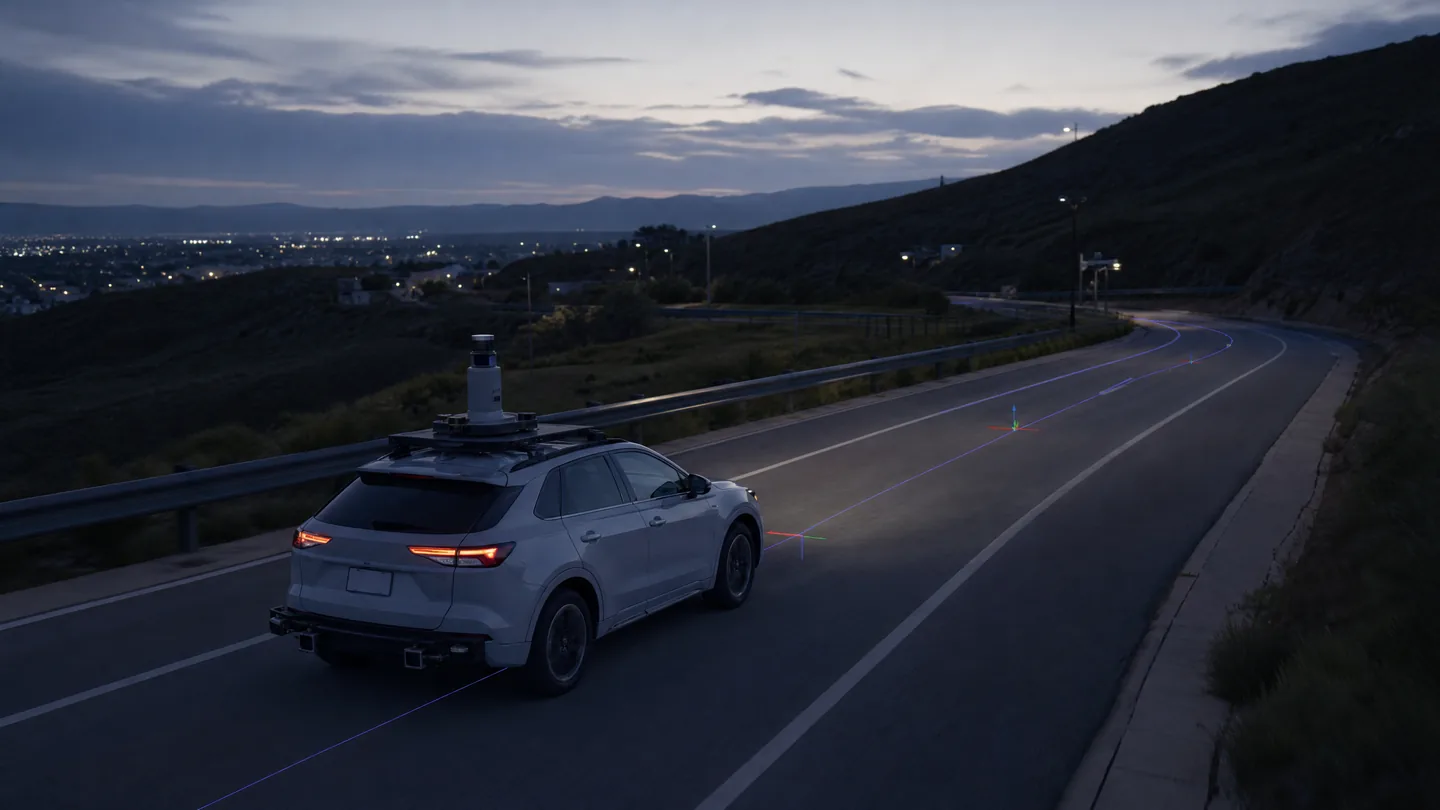
Navigation is an engineering system that connects position, orientation, timing, calibration, and sensor observations. The objective is a coherent trajectory and spatial registration chain for mapping, vehicles, and advanced sensing platforms.
Core technologies
Technologies selected for the job.
GNSS
INS / IMU
Odometry
Timing and synchronization
Sensor calibration
Trajectory processing
Typical workflow
A traceable chain from capture to delivery.
- 01Architect
- 02Integrate
- 03Synchronize
- 04Calibrate
- 05Process
- 06Validate
Key deliverables
Structured outputs for engineering use.
Applications / Industries
Built for real environments and decisions.
Related capabilities
Robotics & Automation
Geospatial intelligence, navigation integration, and mobile sensing for autonomous and semi-autonomous field platforms.
ExploreLiDAR & 3D Reality Capture
High-density three-dimensional capture for terrain, assets, as-built conditions, and digital spatial models.
ExploreTransportation
Corridor-scale capture and positioning for roads, rail, mobility networks, and associated infrastructure.
Explore